
7 cm to 50 cm
Ideal operating range

<1 mm at 7 cm
Minimum object detection

87° × 58°
Wide depth field of viewg

Dual RGB
Advanced AI applications
* The standard D405 ideal range is 7 cm to 50 cm. Perception Studio currently extends D401 and D405 close-range depth to under 3 cm using NVIDIA Jetson.
Built for precision Physical AI at the point of interaction, the RealSense™ D405 is a compact global-shutter stereo depth camera optimized for close-range perception. Its 7 cm to 50 cm ideal range, wide field of view and ability to resolve very small features make it well suited to robotic manipulation, precision positioning, inspection, scanning and measurement. Matched RGB comes from the left depth imager through an onboard ISP, while the RealSense™ Vision Processor D4 performs depth processing on-camera. Perception Studio extends D405 close-range depth to under 3 cm on NVIDIA Jetson.
HARDWARE
Built for Close-Range Physical AI
The D405 is designed for the distances where robots touch, grasp, place and inspect, putting precise 3D geometry at the wrist, gripper, end effector or workcell.
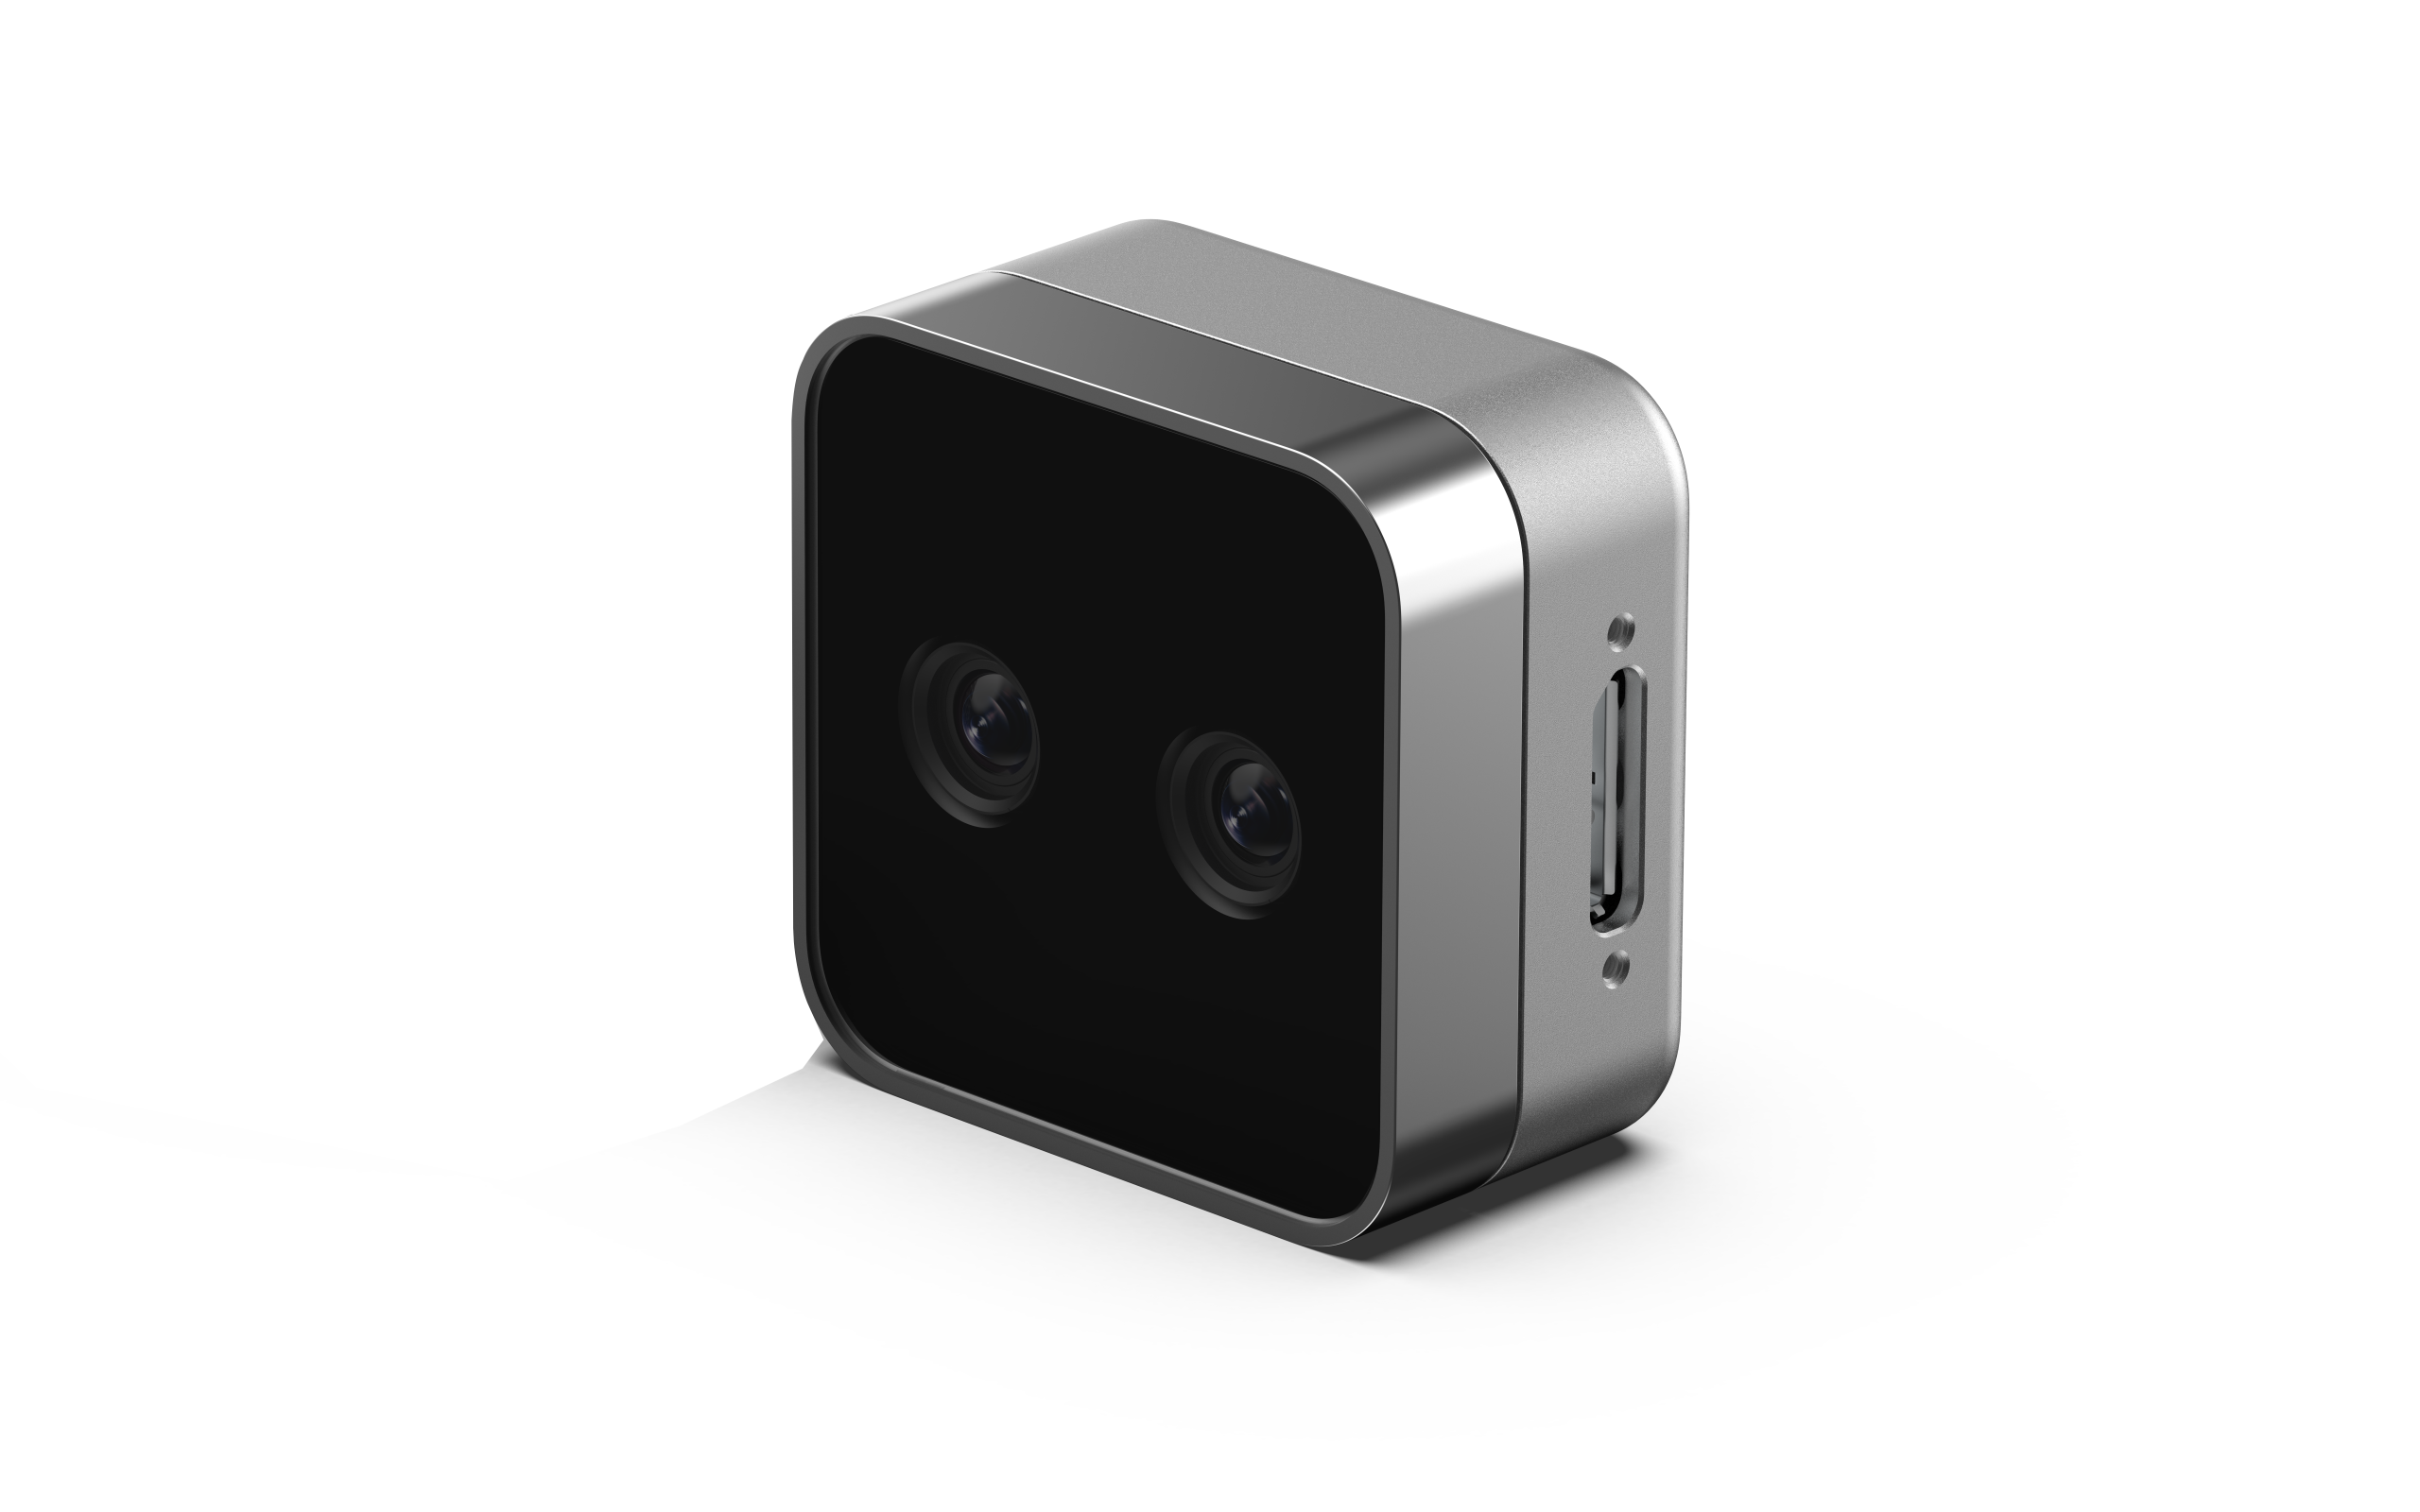
D405
$272
Compact, wide FOV, USB-connected precision 3D stereo depth camera for close-range, manipulator, and inspection applications.
D401 GMSL
Module form factor of our D405, combines precision stereo module with our v6 GMSL ASIC card, now with Dual RGB support (requires Perception Studio).
D401 Module
Module form factor of our D405.
Precision at the Point of Interaction
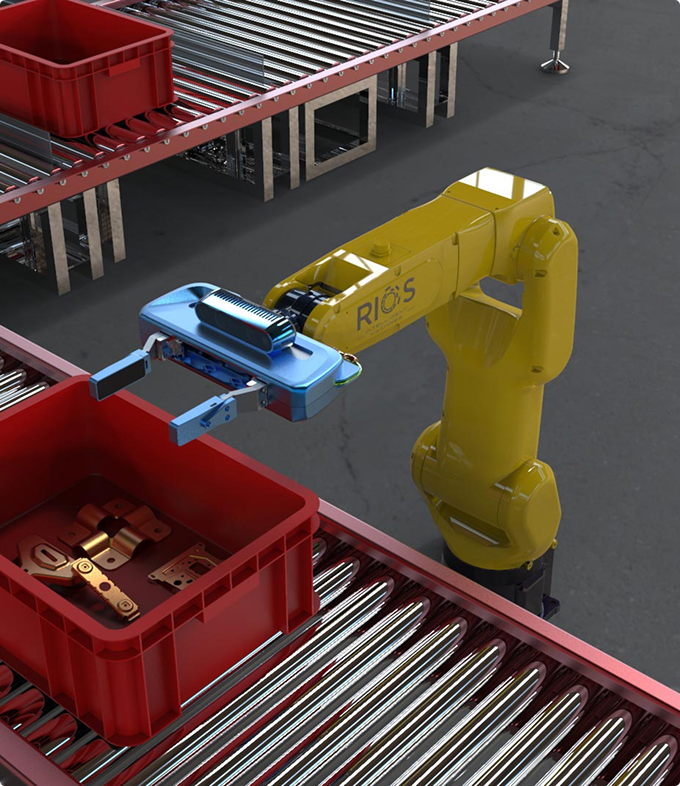
Position, grasp and place with close-range 3D geometry. Mounted on an industrial robot, cobot or humanoid arm, the D405 provides metric depth for object localization, end-effector positioning, grasp planning, pick-and-place, part alignment and assembly verification, keeping useful depth in view through the final centimeters of interaction.
Small Features, High Impact
Resolve fine geometry at working distance. At 7 cm, the D405 can detect features smaller than 1 mm. RealSense also specifies defect-detection performance as fine as 0.1 mm for supported manufacturing scenarios, supporting surface inspection, dimensional checks and small-part handling.
Global-Shutter Depth in Motion
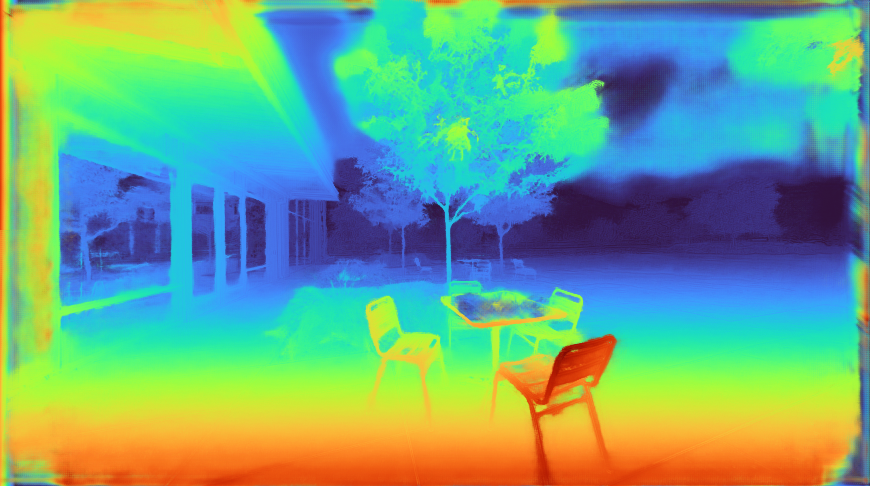
Capture the whole frame at once. Global-shutter stereo imagers reduce motion distortion when the camera, robot arm or target is moving. With depth output up to 90 fps, the D405 can support fast feedback loops for manipulation, positioning and inspection workflows.
Matched Depth and RGB
Color and depth from the same optical path. The D405 uses an onboard image signal processor to generate RGB from the left depth imager, providing matched 87° × 58° color and depth without a separate RGB camera. That simplifies packaging and keeps visual and geometric information closely aligned for close-range perception.
Dual RGB for Teleoperation and AI Training
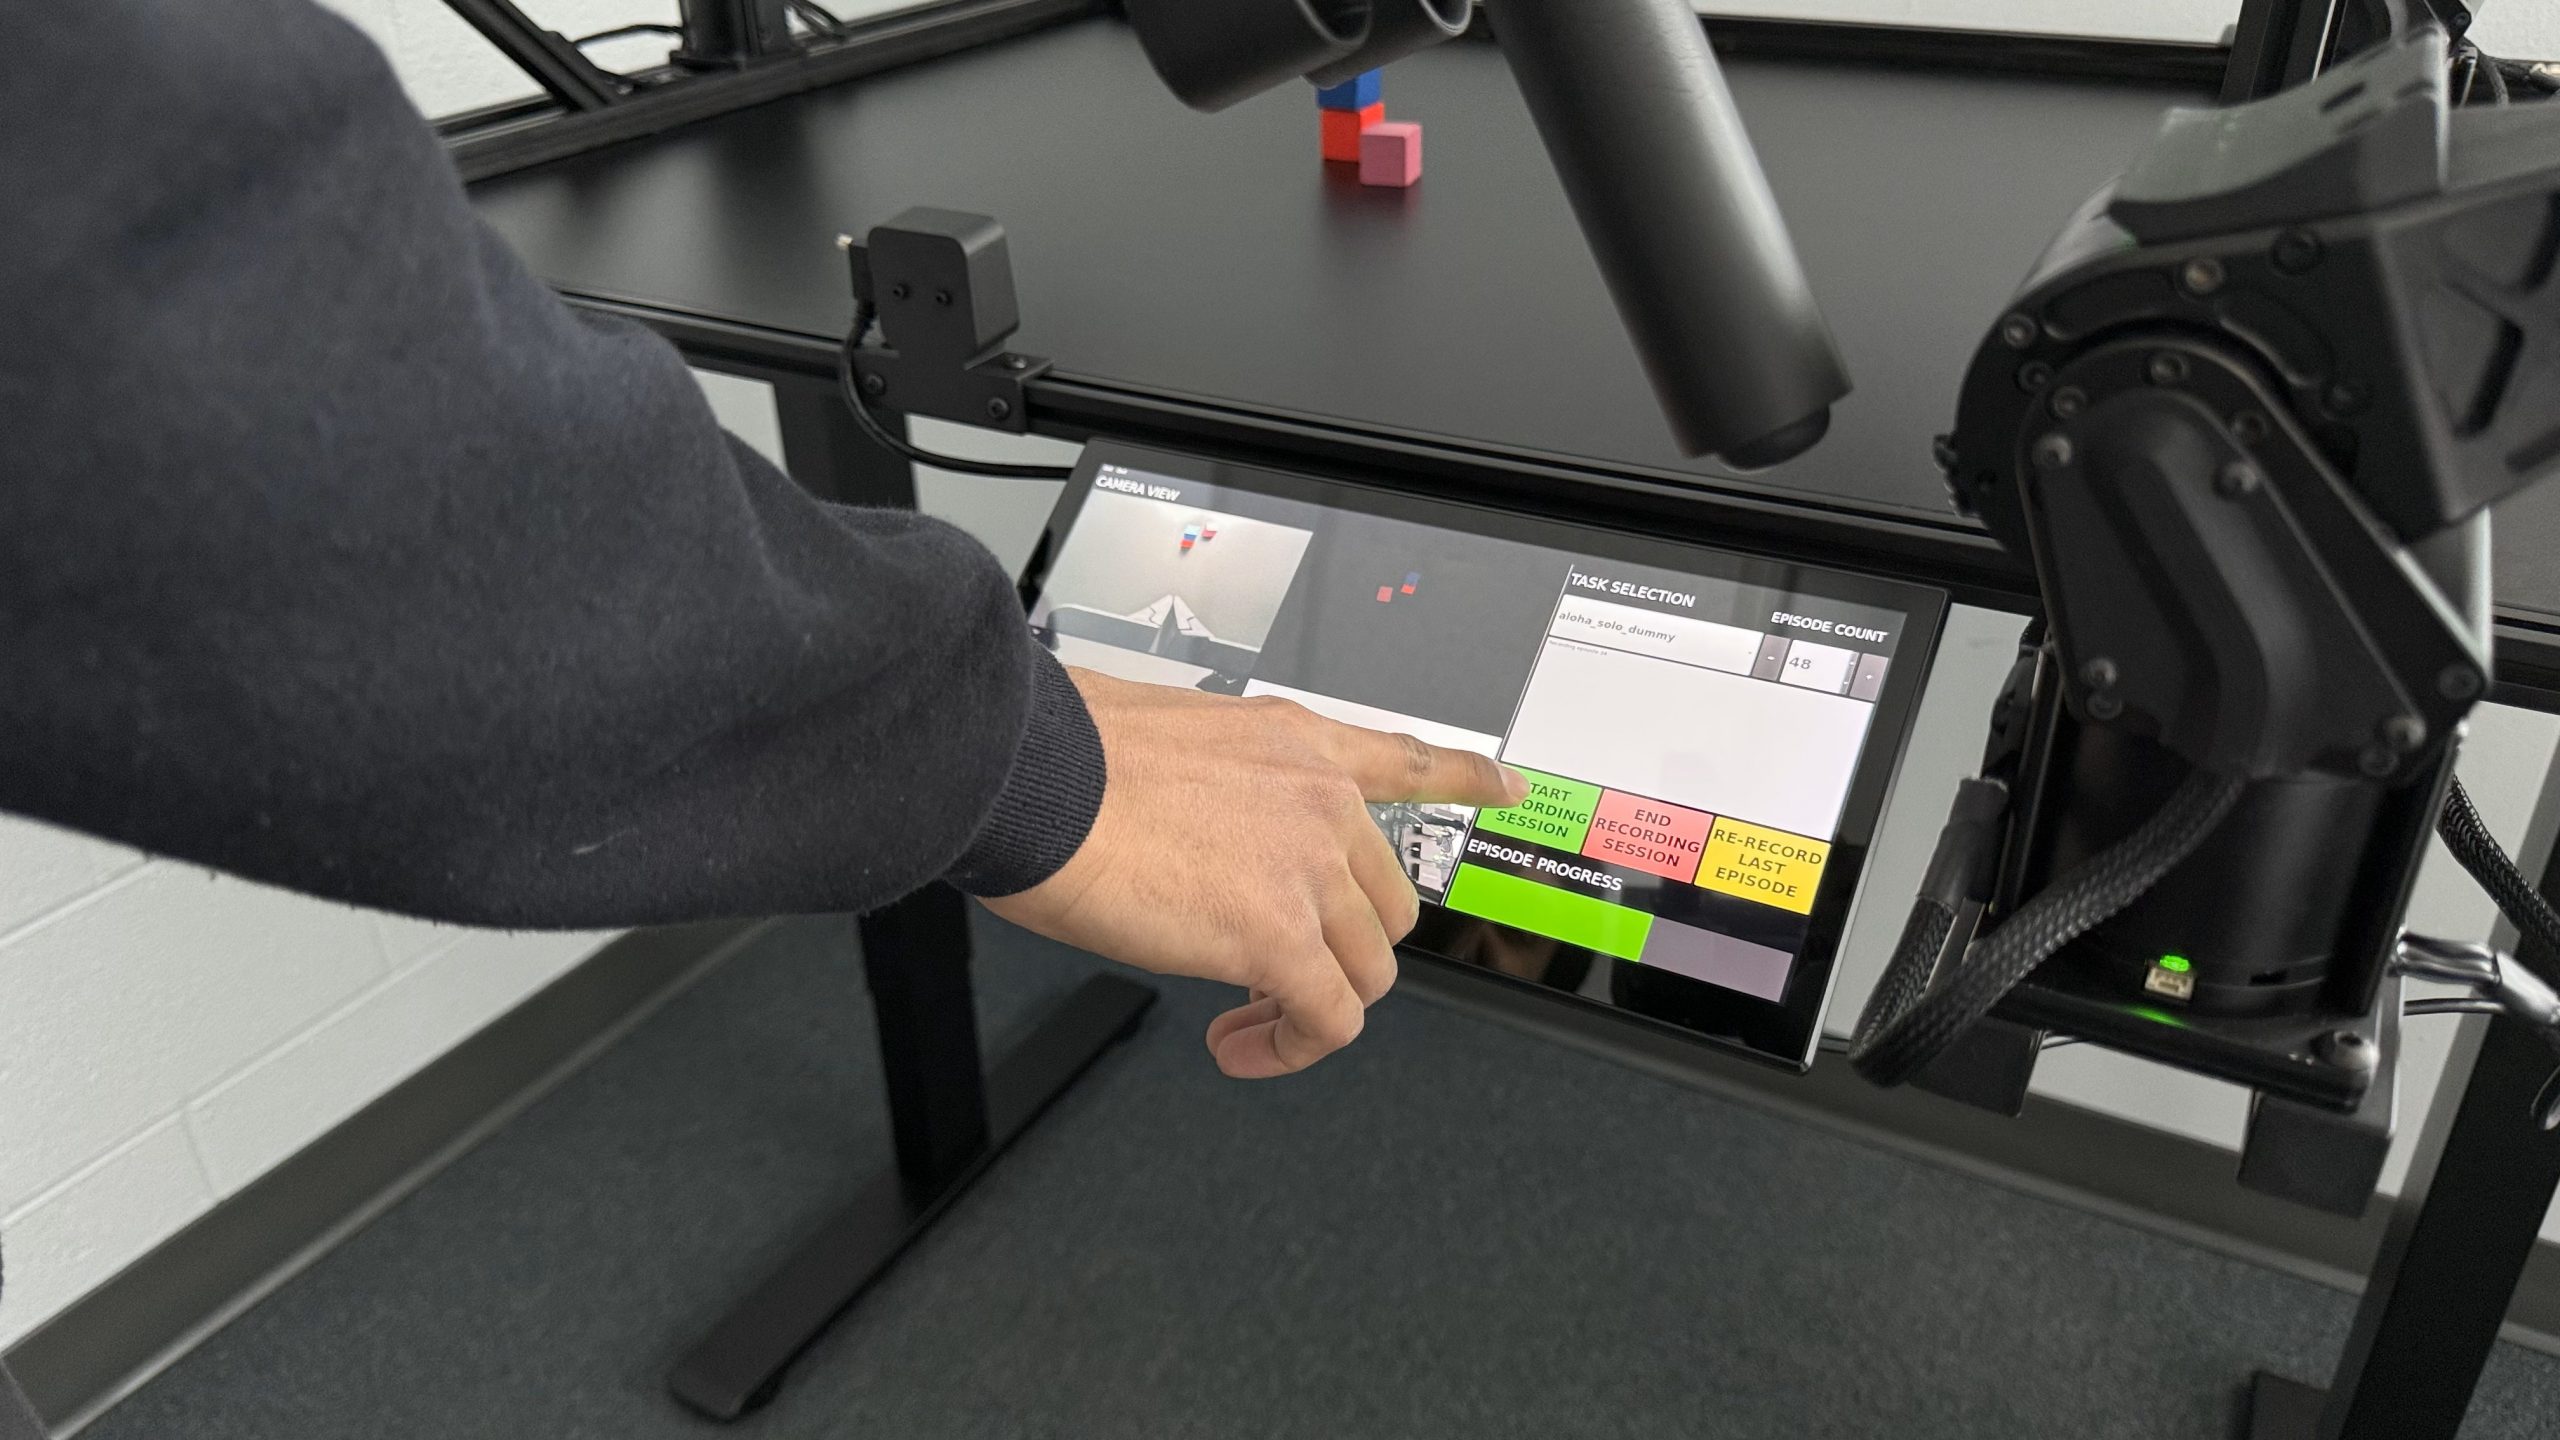
Use one close-range camera from demonstration through deployment. With Perception Studio Dual RGB, synchronized color and depth can support teleoperation while capturing structured RGB-D data for autonomy. Operators gain an intuitive workspace view plus metric 3D information for grasp distance, collision cues and haptic feedback; recorded demonstrations can feed VLA and world-model training using the same sensing geometry deployed on the robot.
Compact by Design
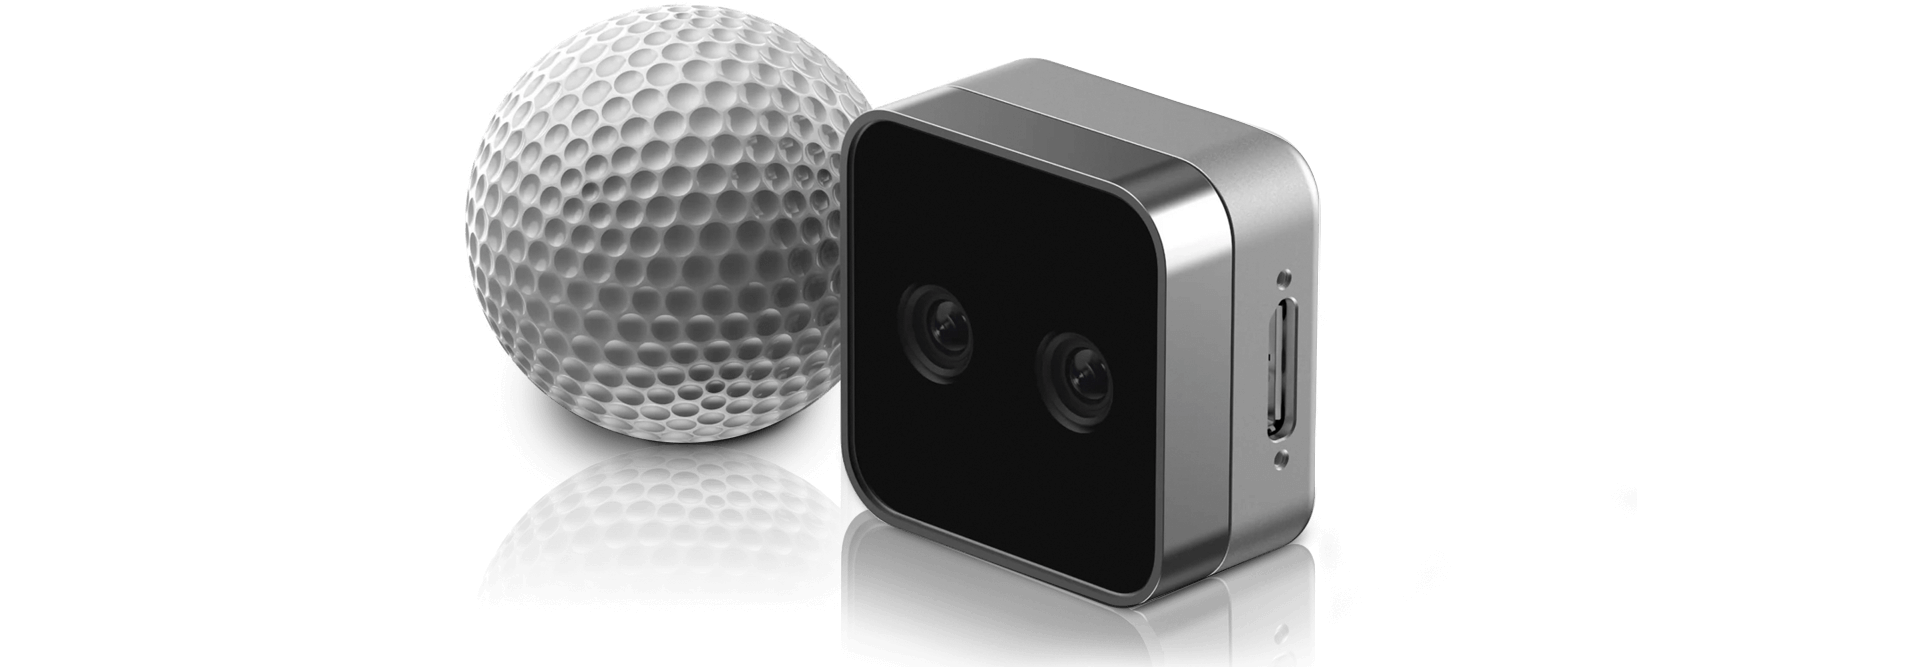
Put precision depth where larger cameras do not fit. At 42 × 42 × 23 mm and 60 g, the D405 is smaller than a golf ball and well suited to wrist-mounted robots, compact workcells and dual-arm research platforms where sensor mass and envelope matter.
Tech Specs
Features
Use environment:
Indoor/Outdoor
Image sensor technology:
Global Shutter
Ideal Range:
7 cm to 50 cm
Inertial measurement unit:
No
Temperature Range:
– 0 to 35 °C (ambient)
– 0 to 55 °C (case)
Depth
Depth Technology:
Stereoscopic
Minimum Depth Distance (Min-Z):
7 cm @ 480p
Depth Accuracy:
+/- 2% at 50 cm
Depth Field of View (FOV):
87° × 58°
Depth Output Resolution:
Up to 1280 × 720
Depth Frame Rate:
Up to 90 fps
RGB
Technology:
Left imager RGB with ISP
RGB Frame Rate:
Up to 90 fps
RGB Frame Resolution:
1280 × 720
RGB Sensor Technology:
Global Shutter
RGB Resolution and Frame Rate:
1280 × 720 at 30 fps
RGB Sensor FOV (H x V):
87° × 58°
Power and Connectors
Power:
Idle: 35 mW
Streaming: 1.55 W (Depth + IR)
Major Components
Camera Module:
RealSense Module D401
Vision Processor Board:
RealSense Vision Processor D4 Board v4
Physical
Form Factor:
Peripheral/Module
Length x Depth x Height:
– 42 mm × 42 mm × 23 mm (Peripheral)
– 36.5 mm × 19.4 mm × 10.5 mm (Module)
Connectors:
– USB 2
– USB 3.1
Mounting Mechanism:
– One 1/4‑20 UNC thread mounting point
– Two M3 thread mounting points
Leveraging the power of SDK 2.0
Build with the open-source RealSense™ SDK 2.0 and a common set of depth tools, APIs and integrations. It supports Windows, Linux, Android and macOS, with wrappers for Python, ROS, C/C++, C#, Unity, Unreal, OpenNI and Node.js. Depth computation runs on the RealSense Vision Processor D4, reducing host-side stereo processing requirements.