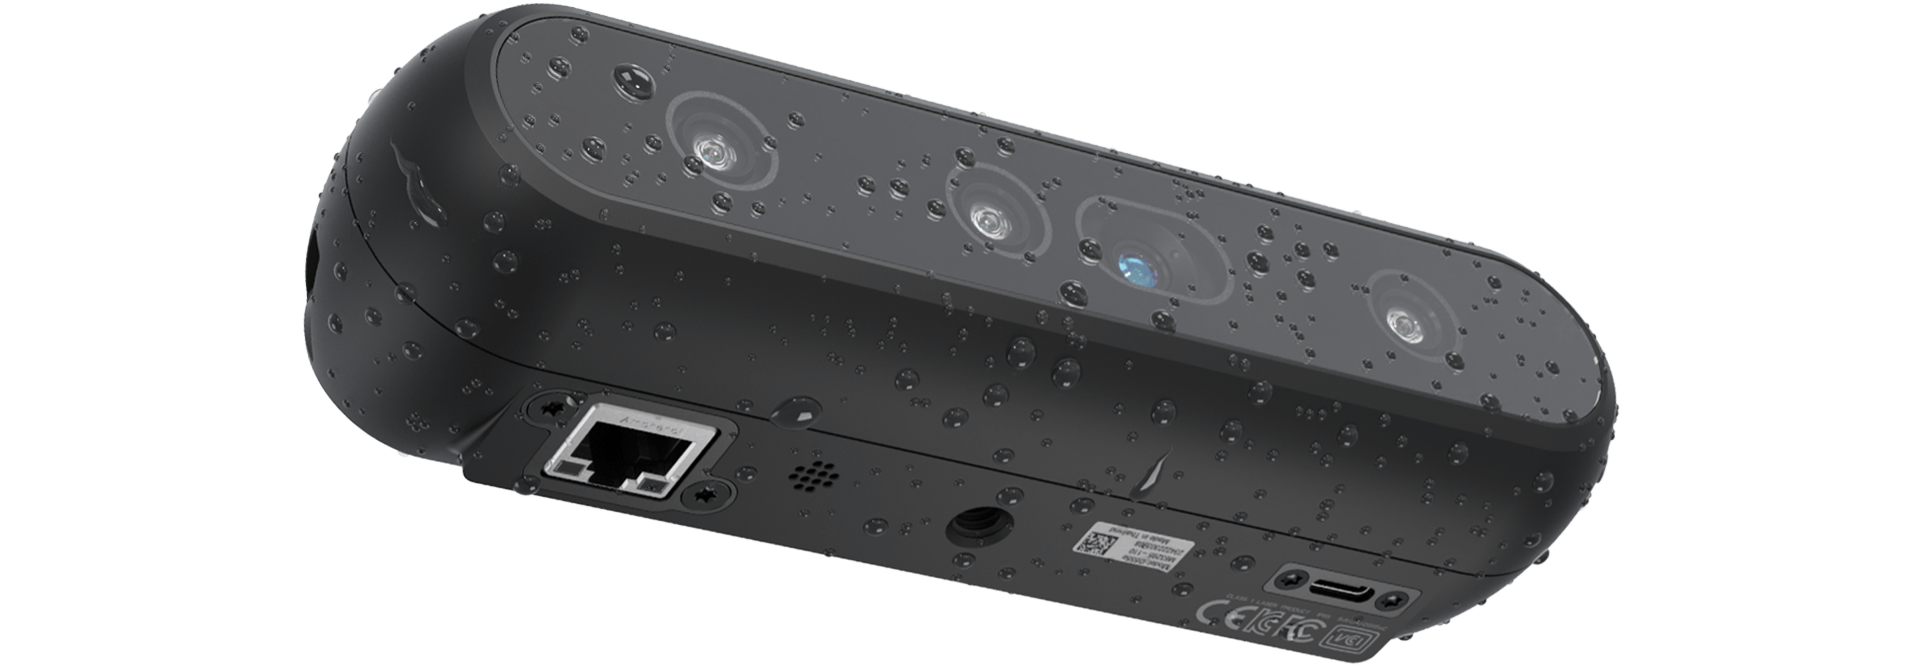

PoE / RJ45
Power + data over Ethernet

Up to 100 m
Industrial Ethernet cable reach

IP65
Dust-tight, protected from projected water

Vision SoC V5
Next-generation vision processing
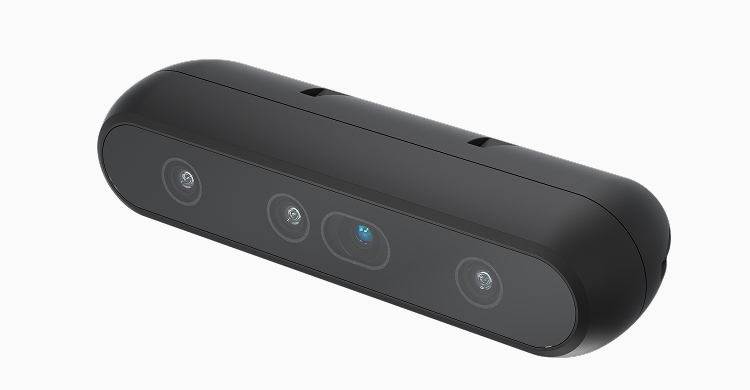
The RealSense™ D555 brings 3D perception onto the industrial network. It is the first RealSense camera powered by the Vision SoC V5 and the first with native Power over Ethernet (PoE), combining the long-range D450 global-shutter depth module, matched global-shutter RGB, integrated IMU and an IP65 enclosure in a single network-connected camera. Vision SoC V5 adds stereo disparity processing, motion estimation, a vision DSP and the IPU7 image signal processor for geometric distortion correction and temporal noise reduction, creating an AI-native platform for robotics, machine vision and software-defined perception, including native on-camera People Detection.
HARDWARE
Industrial Vision, Network-Native
The D555 is designed for systems where cameras are part of the robot or factory network, not just a USB peripheral. One Ethernet connection can carry both power and data, while native ROS 2 streaming and onboard vision processing reduce integration friction in distributed perception systems.
Power and Data on One Cable
Deploy cameras where the application needs them. Native PoE simplifies cabling and connects directly to standard Ethernet infrastructure. RealSense specifies reliable industrial Ethernet operation over cables up to 100 meters, making D555 useful for large workcells, production lines, mobile machines and distributed multi-camera installations.
Native ROS 2 Over Ethernet
Stream directly into the robot software stack. D555 uses SafeDDS, an ISO 26262-certified DDS implementation interoperable with Fast DDS, the middleware used by ROS 2. The camera can stream over Ethernet to ROS 2 nodes on the network without requiring a USB connection or separate bridge application.
Bandwidth-Efficient RGB-D Streaming
Ethernet makes it practical to distribute perception across a robot, vehicle or facility, but raw RGB-D streams can consume substantial bandwidth. D555 supports H.264 compression for RGB and RealSense Depth Compression with selectable 4:1 or 9:1 ratios, reducing network load for multi-camera systems, remote compute and autonomous platforms while retaining the depth data needed by downstream perception and control.
Dual RGB for Teleoperation, Training and Spatial AI
With Dual RGB enabled through Perception Studio, D555 combines two synchronized, spatially separated color views with accurate spatial position. Its 95 mm stereo baseline is well suited to mobile robots, autonomous forklifts, remote inspection and large-workspace teleoperation, providing richer multi-view context at working distance. For VLA and world-model training, synchronized multi-view RGB-D demonstrations preserve scale and geometry while using the same camera for collection and deployment, helping reduce the train-to-deploy gap.
Vision SoC V5
More than a depth processor. Vision SoC V5 combines stereo disparity processing, motion estimation, a computer-vision-optimized DSP and the IPU7 ISP. IPU7 improves RGB with geometric distortion correction and temporal noise reduction, while optimized neural-network processing provides headroom for increasingly software-defined perception capabilities.
Native On-Camera People Detection
D555 can detect people directly on the camera, moving a common perception workload from the host into the vision device itself. For robot workcell monitoring, autonomous forklifts, AMRs and other systems operating around people, native People Detection can be combined with depth-derived 3D position and distance to support proximity-aware behavior and reduce the amount of image data that must be processed elsewhere in the system.
Rugged, Global-Shutter Sensing
Built for motion and industrial environments. The D555 combines global-shutter stereo depth and RGB with an integrated IMU in an IP65 enclosure rated for a -20°C to 50°C operating case temperature. That makes it well suited to robots and machine-vision systems operating around motion, dust and changing environmental conditions.
Made for Industrial Physical AI
D555 combines network connectivity, ruggedization and 3D sensing for applications that need perception to extend across a workcell, production line or mobile machine.
Advanced Industrial Machine Vision
Move from images to measurable 3D understanding. Use synchronized global-shutter RGB and depth for object localization, dimensional reasoning, volume estimation, process monitoring and AI-based inspection. PoE makes it practical to place cameras around large machines or production areas while keeping compute centralized on the network.
Robot Workcell and Space Monitoring
Give robots continuous awareness of the space around them. Native on-camera People Detection identifies people at the edge, while depth provides accurate spatial position so the system can understand where they are relative to the robot. Fixed or distributed D555 cameras can also provide 3D position and distance for parts, carts and other objects around a workcell, feeding workspace models, proximity logic, dynamic zones and higher-level orchestration so robot behavior reflects what is actually happening in the shared environment.
Robotic Arm Guidance and Pick-and-Place
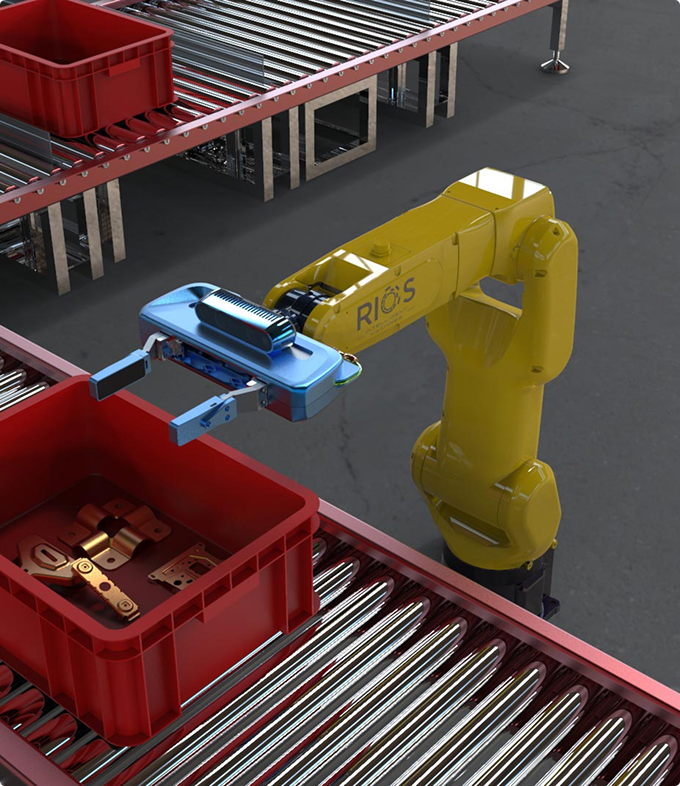
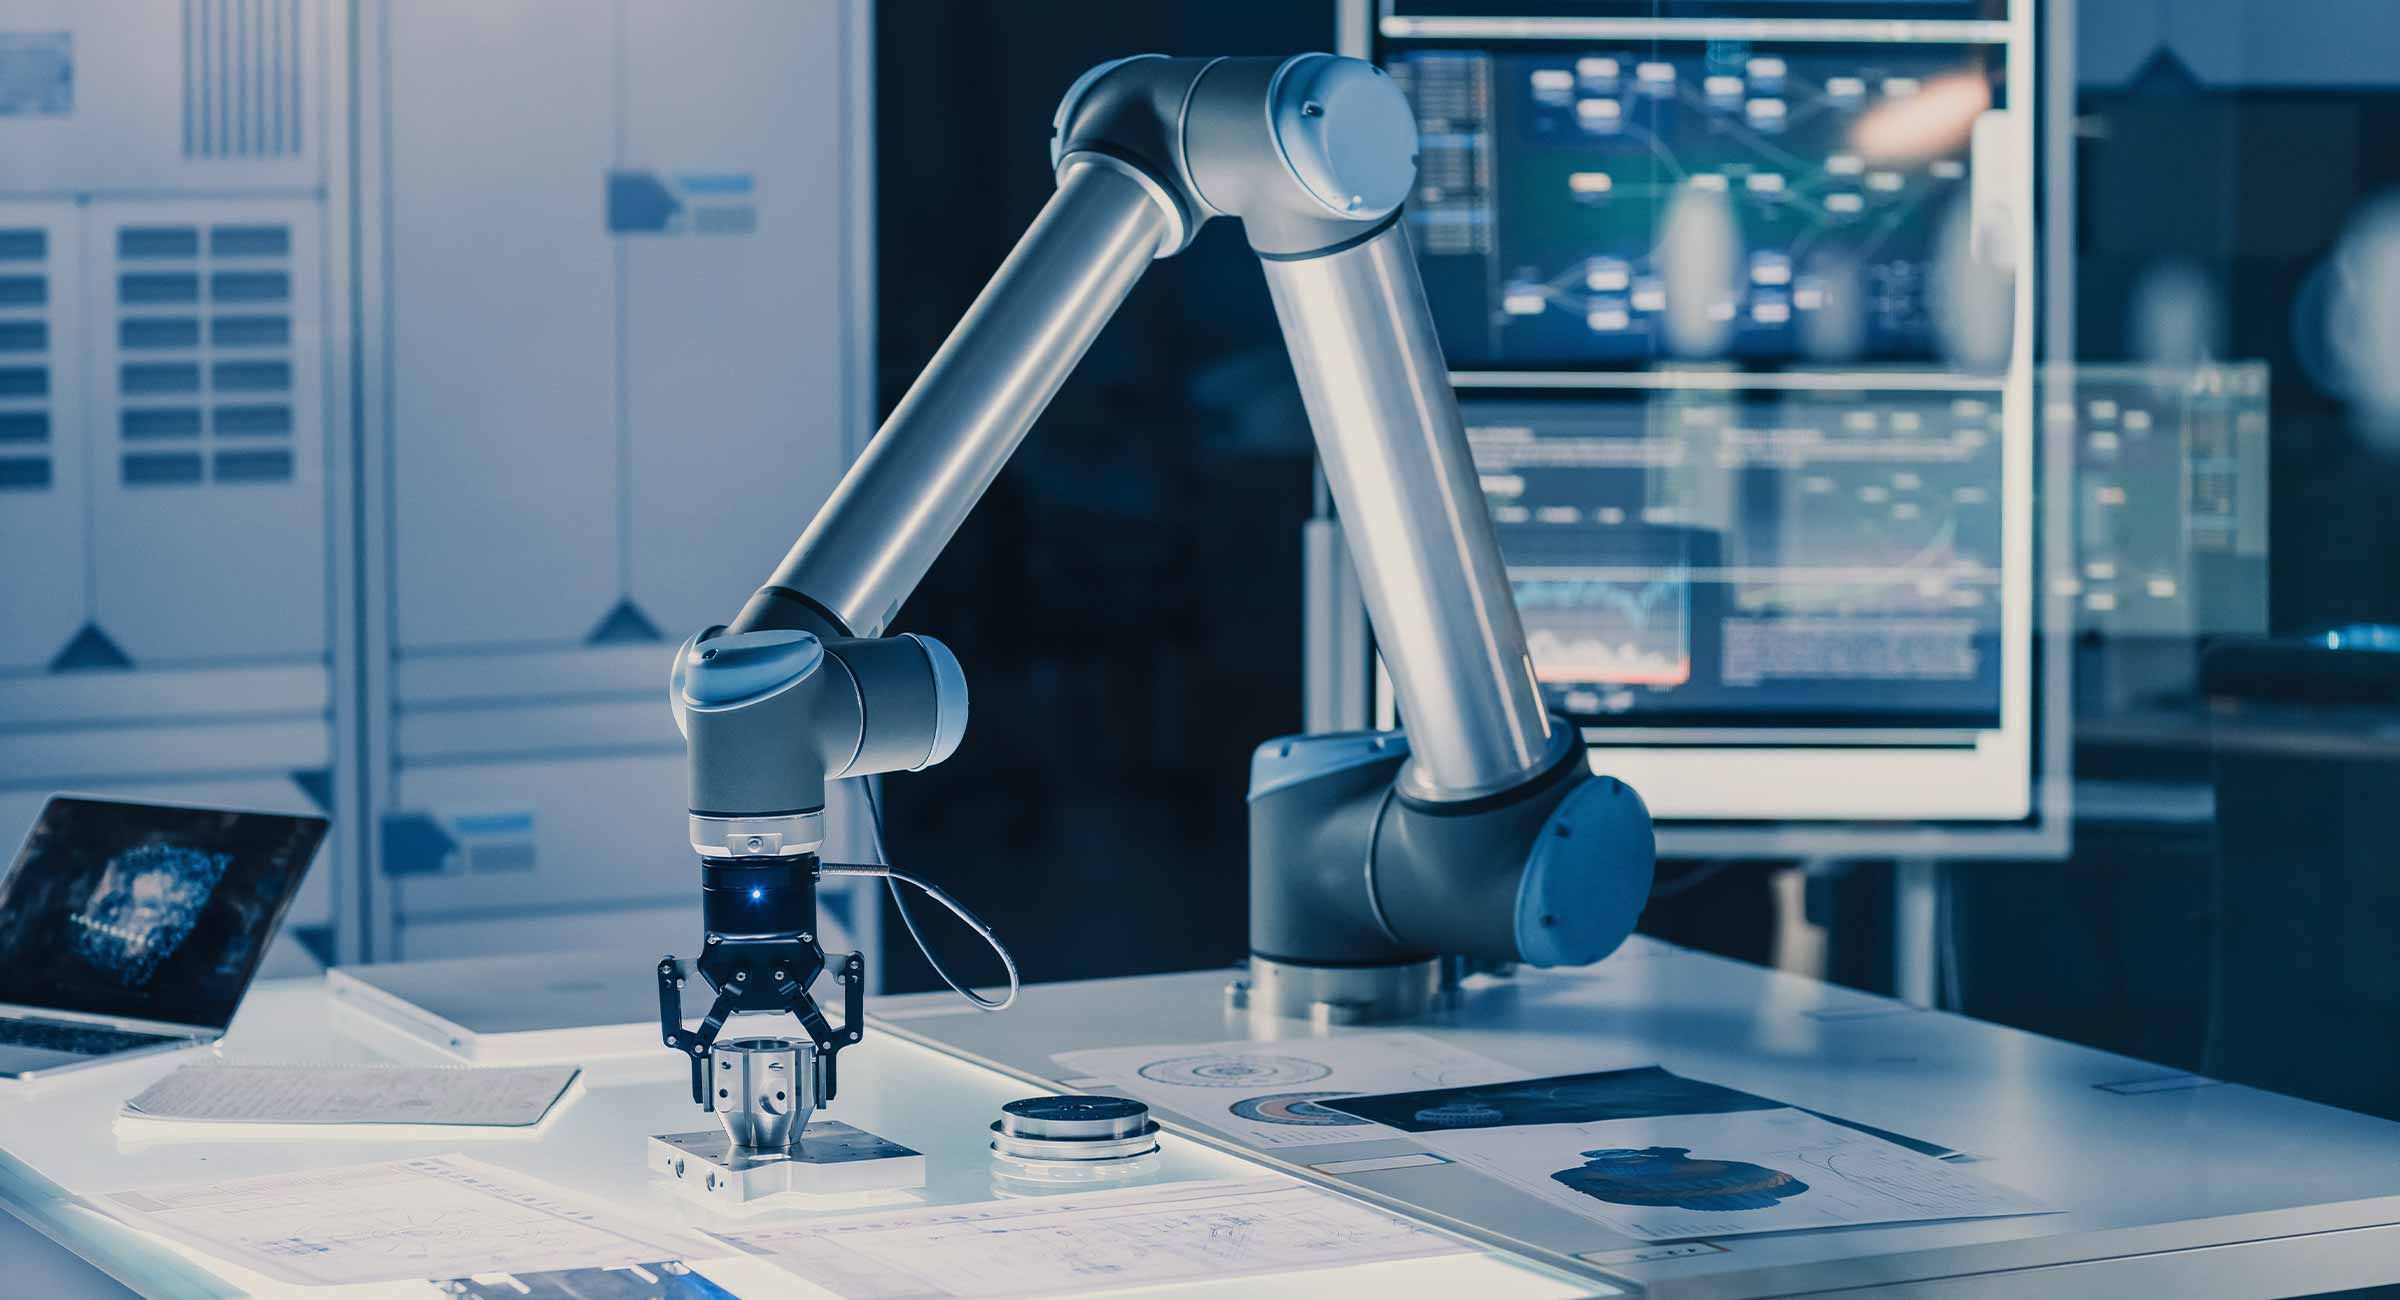
Use depth to close the loop between perception and motion. 3D vision can localize parts, estimate grasp points, transform detections into robot coordinates and verify placement without requiring every component to be mechanically staged. This supports bin picking, part transfer, assembly, machine tending and other flexible automation workflows.
Autonomous Forklifts, AMRs and Industrial Vehicles
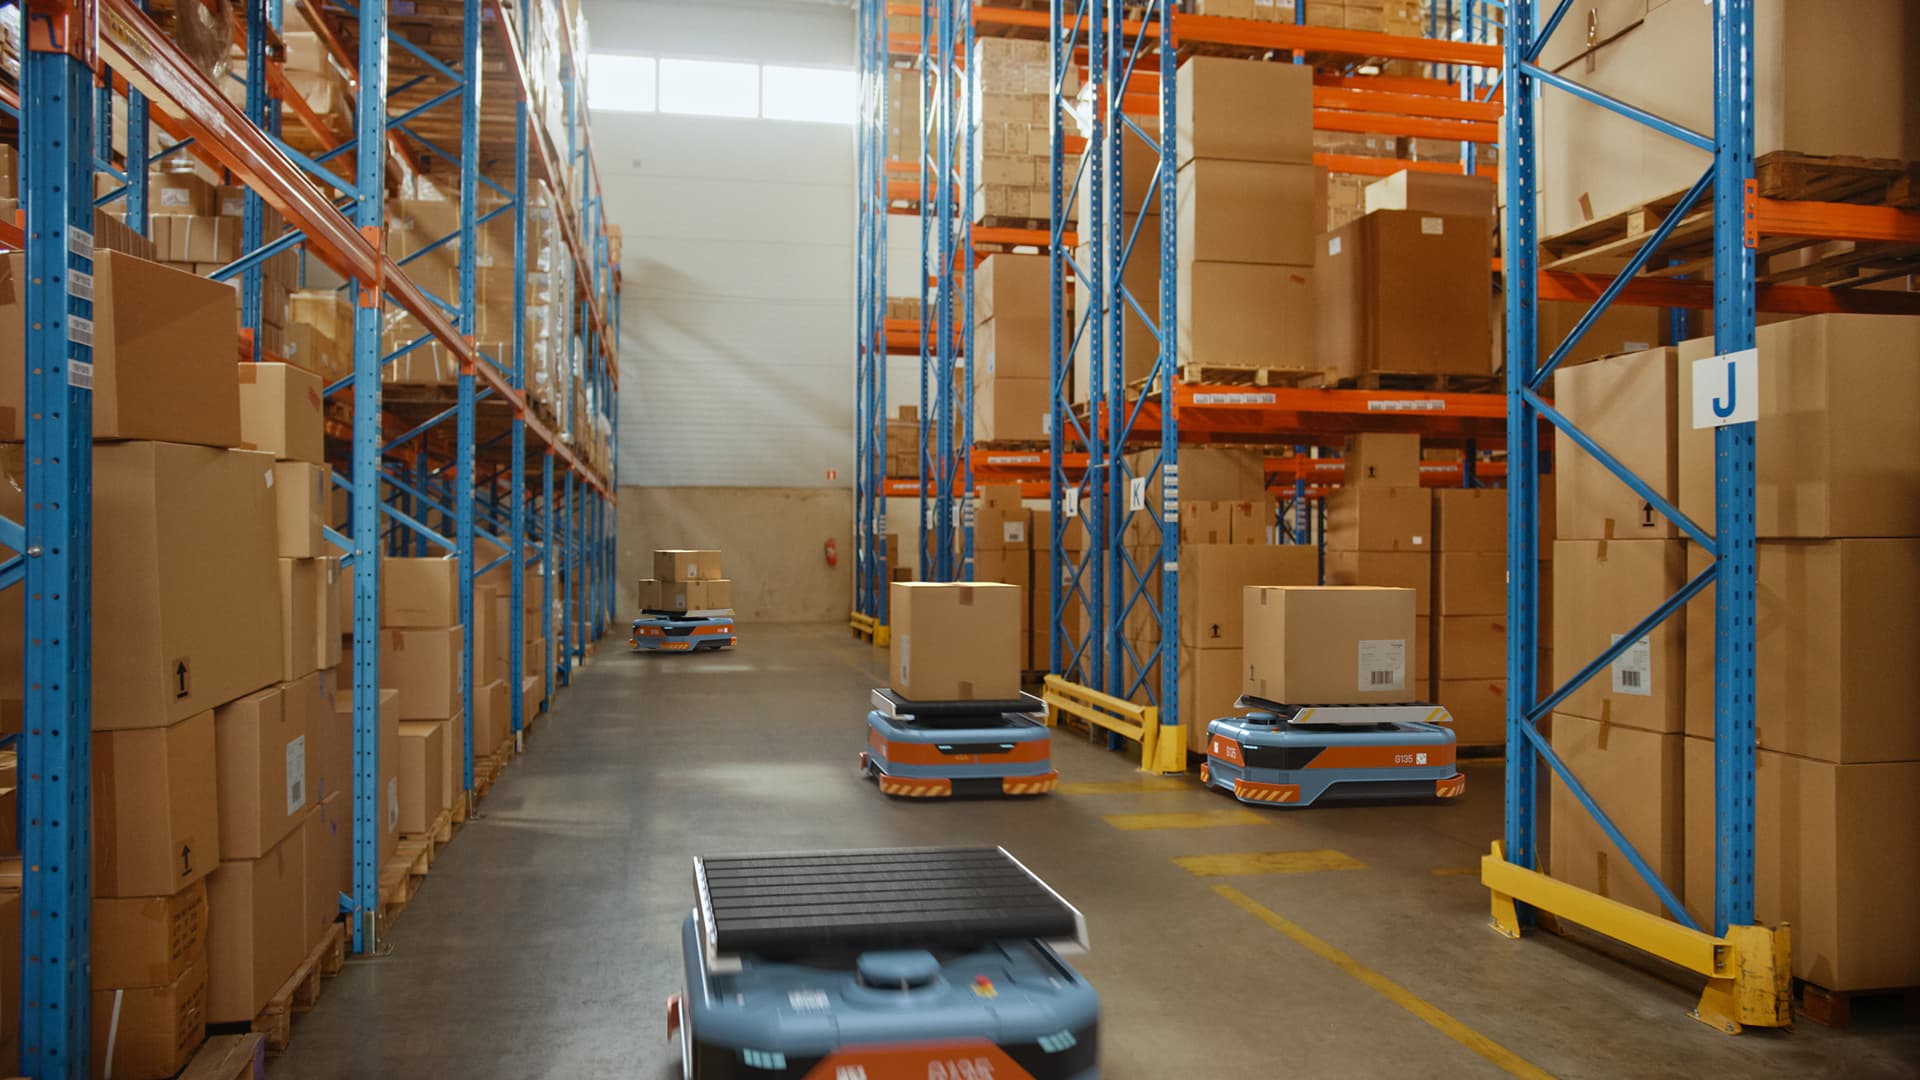
Network multiple viewpoints across a moving platform. Global-shutter depth, RGB and IMU data can support obstacle detection, pallet and load perception, docking, localization and navigation, while native on-camera People Detection adds an edge-level signal for awareness of operators and pedestrians around the vehicle. PoE enables cameras to share onboard Ethernet infrastructure, while IP65 packaging supports deployment on industrial mobile systems exposed to dust and projected water.
Distributed Multi-Camera Perception
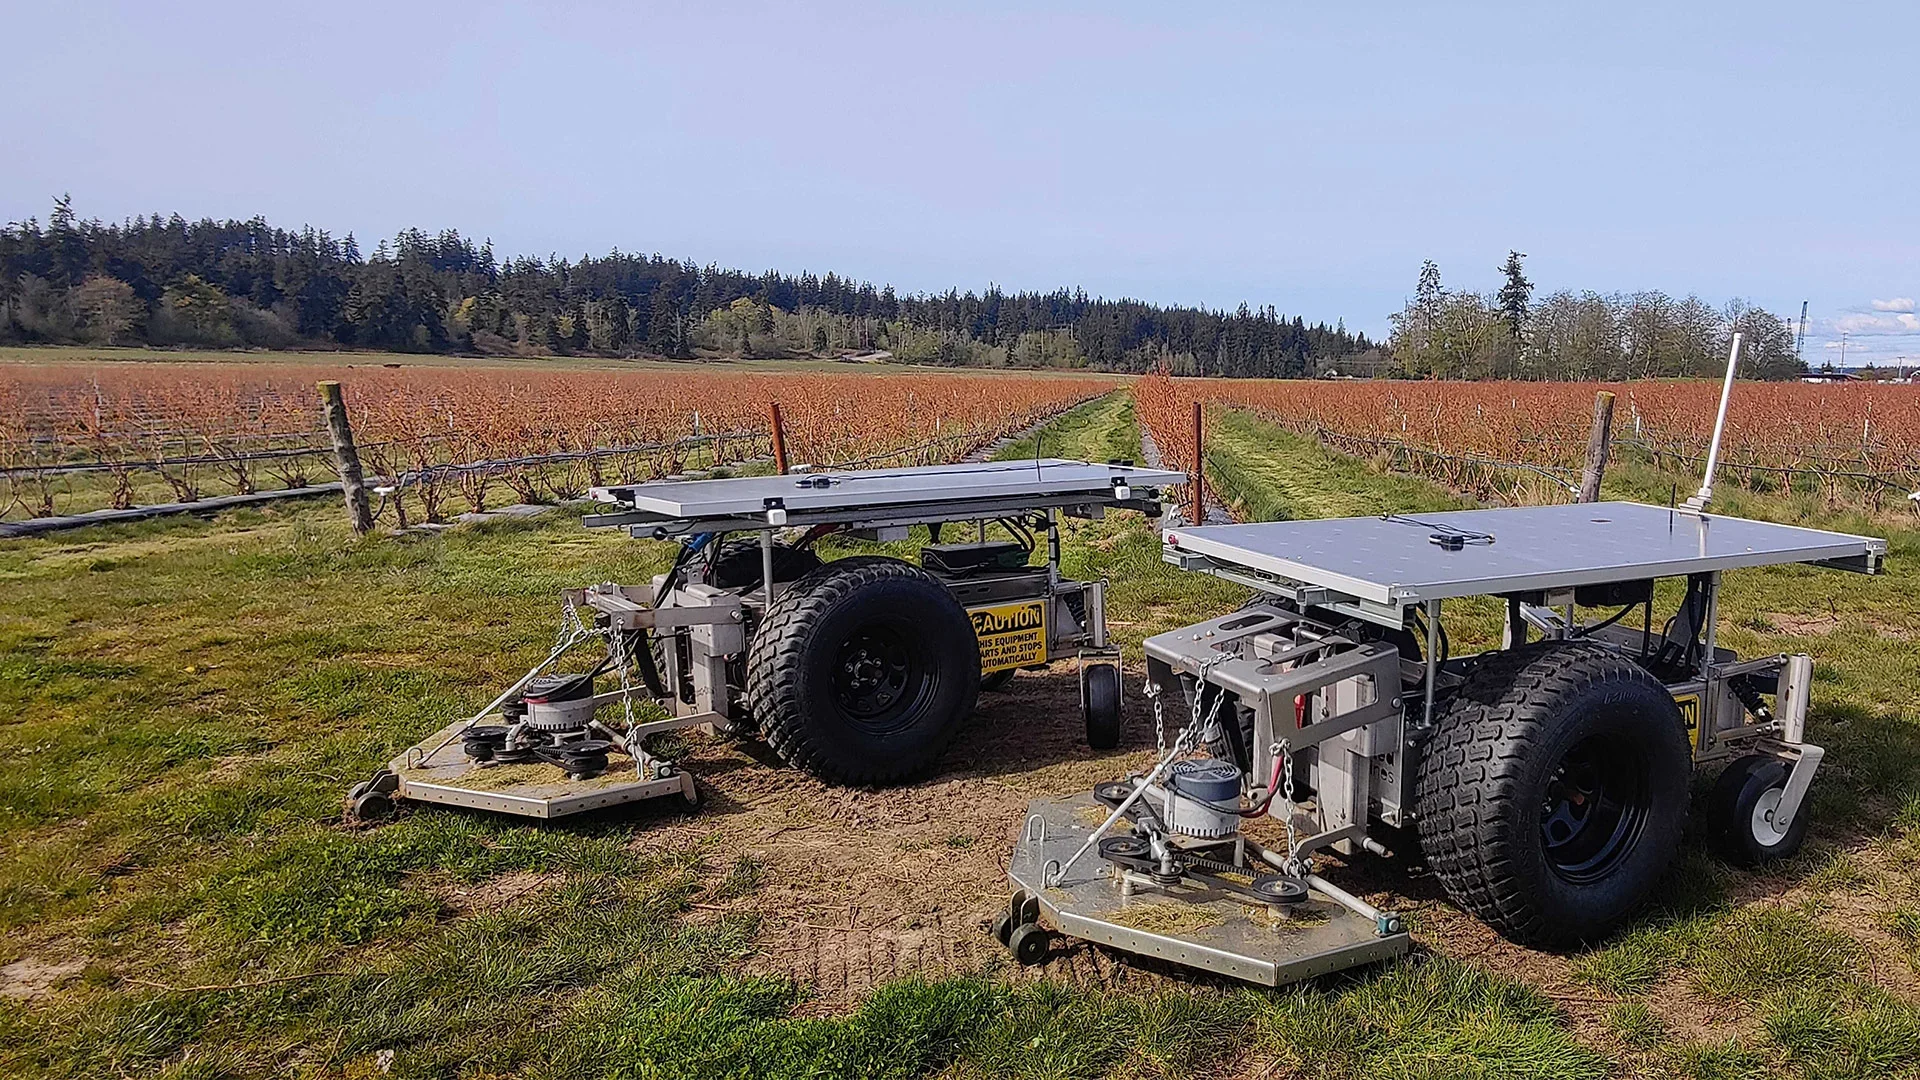
Scale beyond a single viewpoint. D555 supports low-latency multi-camera deployments over Ethernet, allowing a system to combine views around a machine, workcell or robot. Long cable reach lets perception be placed where it is most useful, while compressed RGB-D streaming helps reduce per-camera network bandwidth as deployments scale.
Tech Specs
Features
Use environment:
Indoor/Outdoor
IP Grade:
Rated IP65
Image sensor technology:
Global Shutter
Operating Case Temperature:
-20° to 50°C
Depth
Depth Technology:
Stereoscopic
Minimum Depth Distance (Min-Z):
~26 cm (VGA)
Depth Field of View (FOV):
87° × 58°
Depth Output Resolution:
Up to 1280 × 720
Depth Frame Rate:
Up to 90 fps
RGB
RGB Frame Rate:
Up to 60 fps
RGB Frame Resolution:
Up to 1280 × 800
RGB Sensor Technology:
Global Shutter
RGB Sensor FOV (H x V):
90 × 65°
Power and Connectors
PoE Connector:
RJ45
USB Connector:
USB-C1 (Can be used for power)
Power (Typical):
5.5W
External HW Sync:
Via the USB connector
Major Components
Camera Module:
RealSense Module D450
Vision Processor Board:
RealSense Vision SoC V5 RealSense Vision SoC V5 Board 1
Physical
Form Factor:
Camera Peripheral
Length x Depth x Height:
167 mm × 42 mm × 48 mm
Leveraging the power of
SDK 2.0
Build the future with the open source RealSense™ SDK 2.0 and depth tools. Platform independent, the SDK supports all current RealSense depth cameras and includes wrappers for many common platforms and languages.